Trail Tracer:
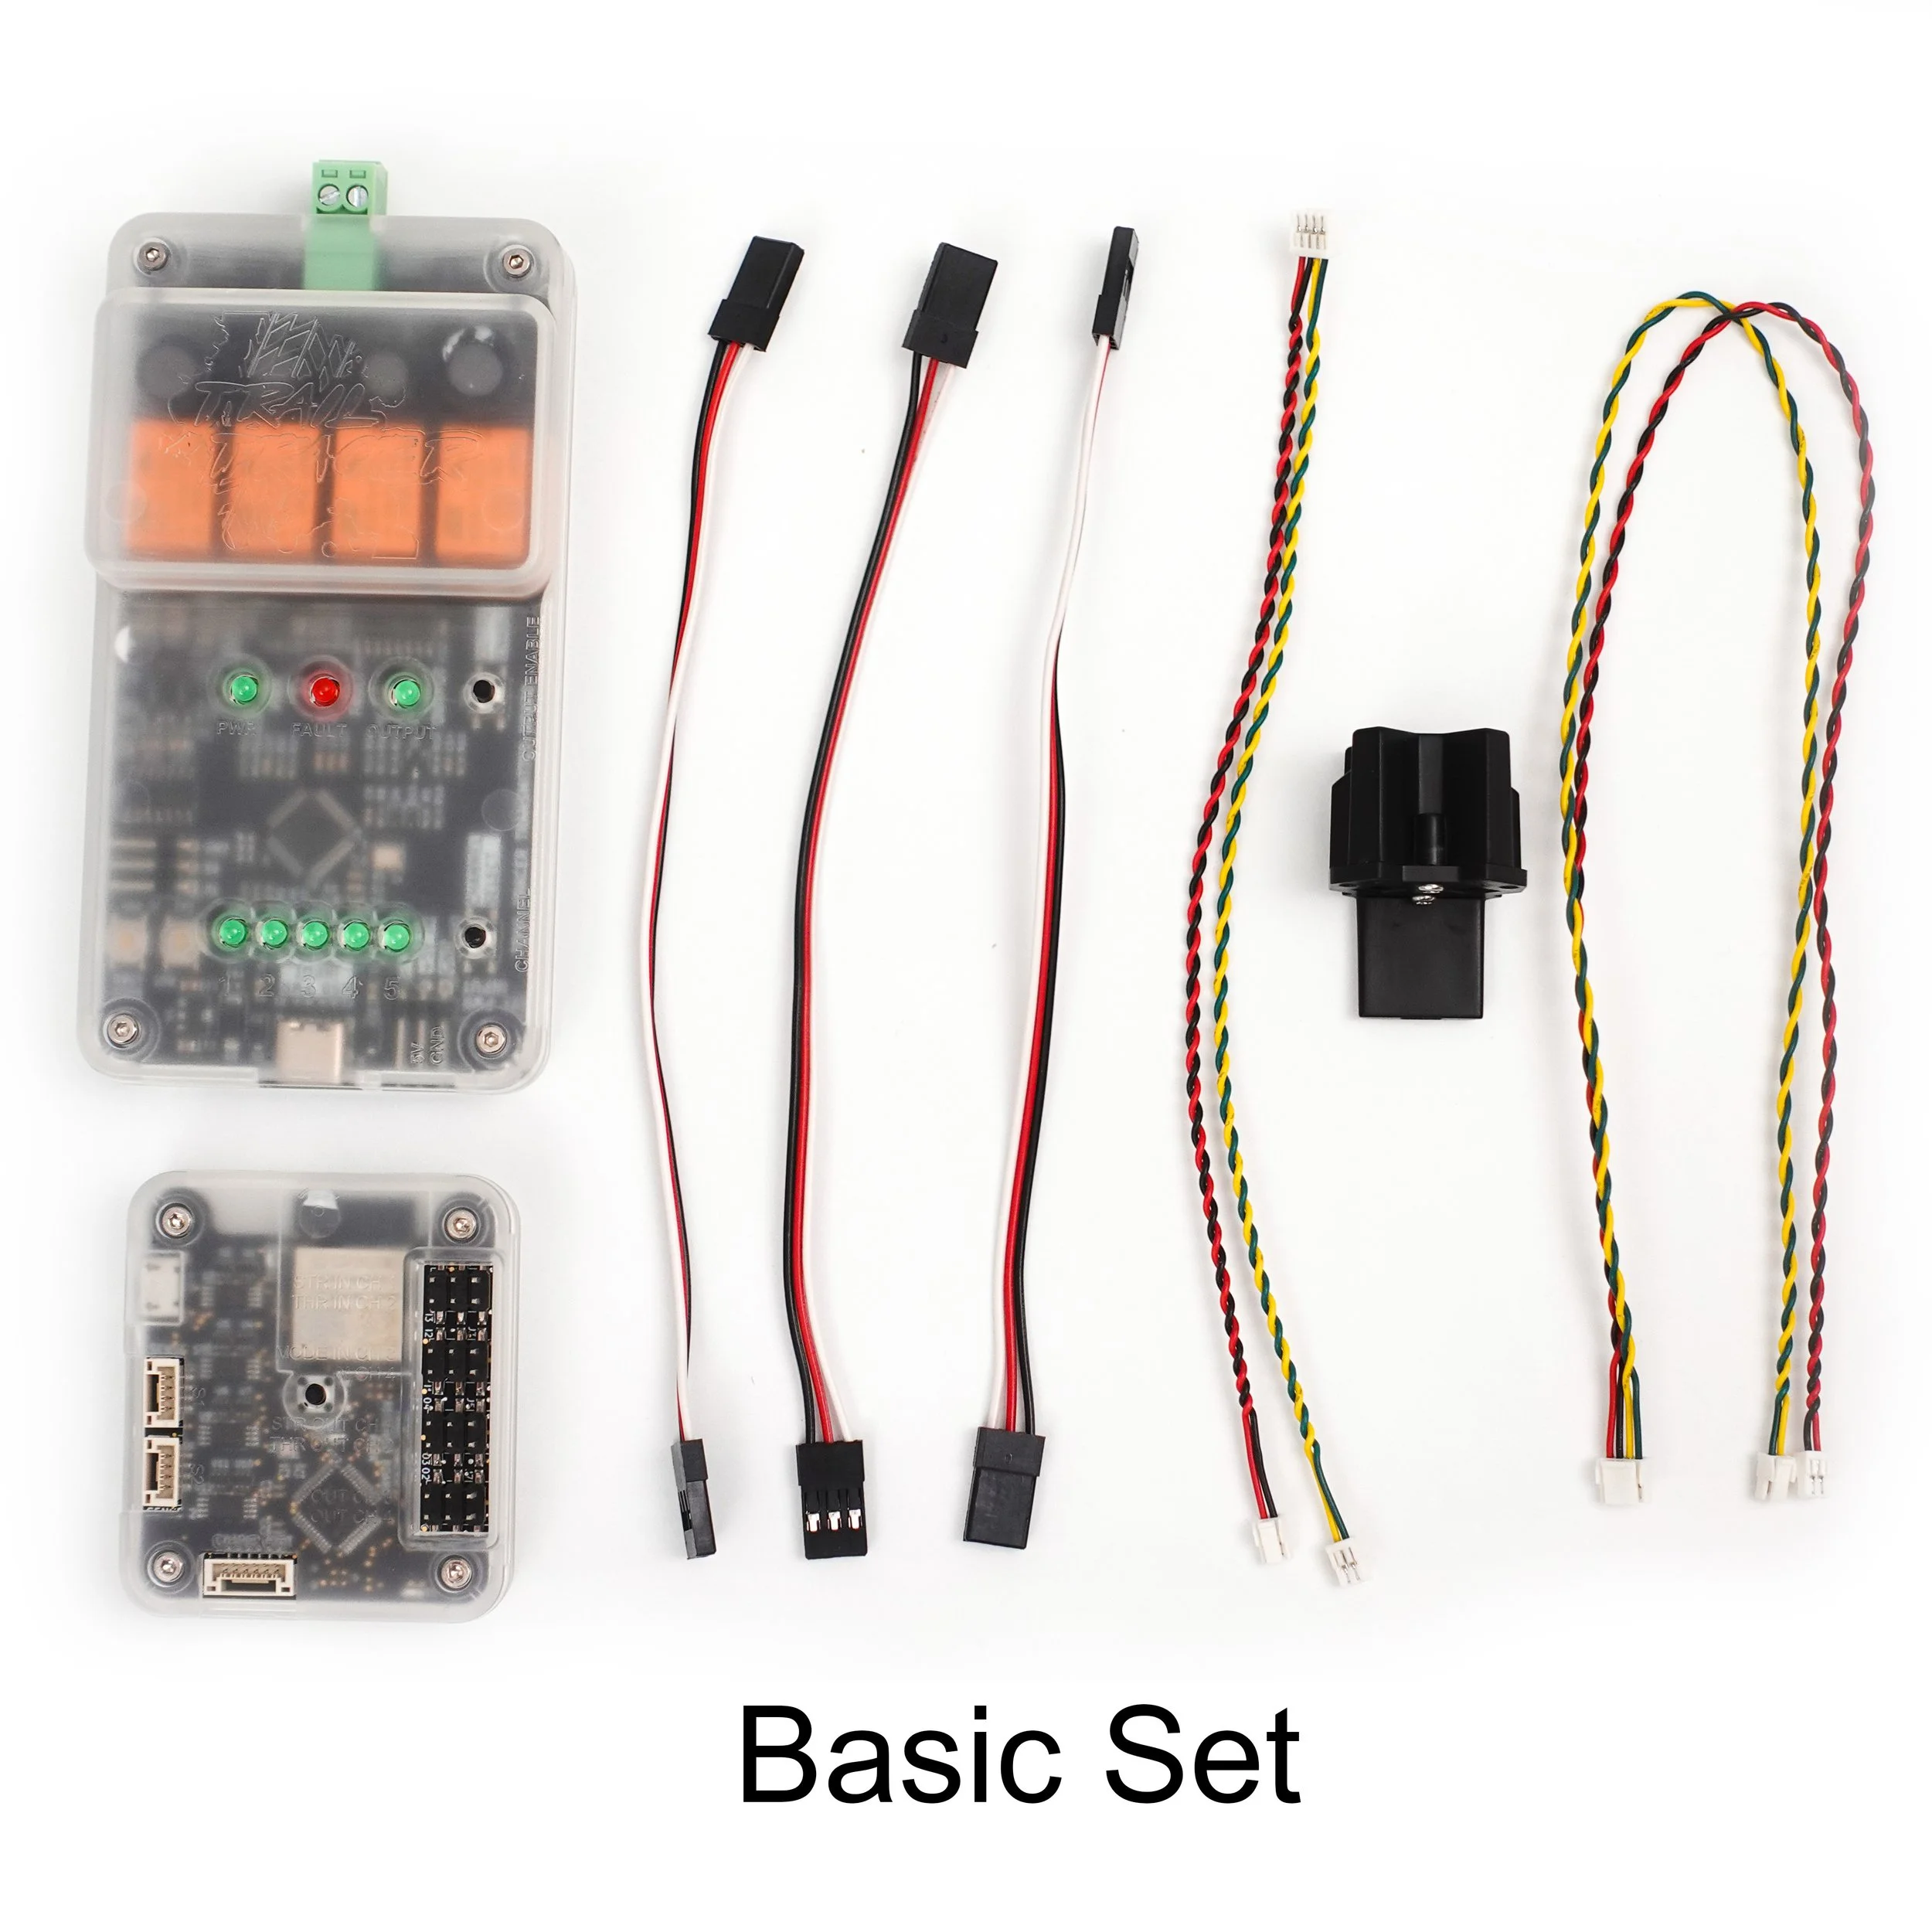
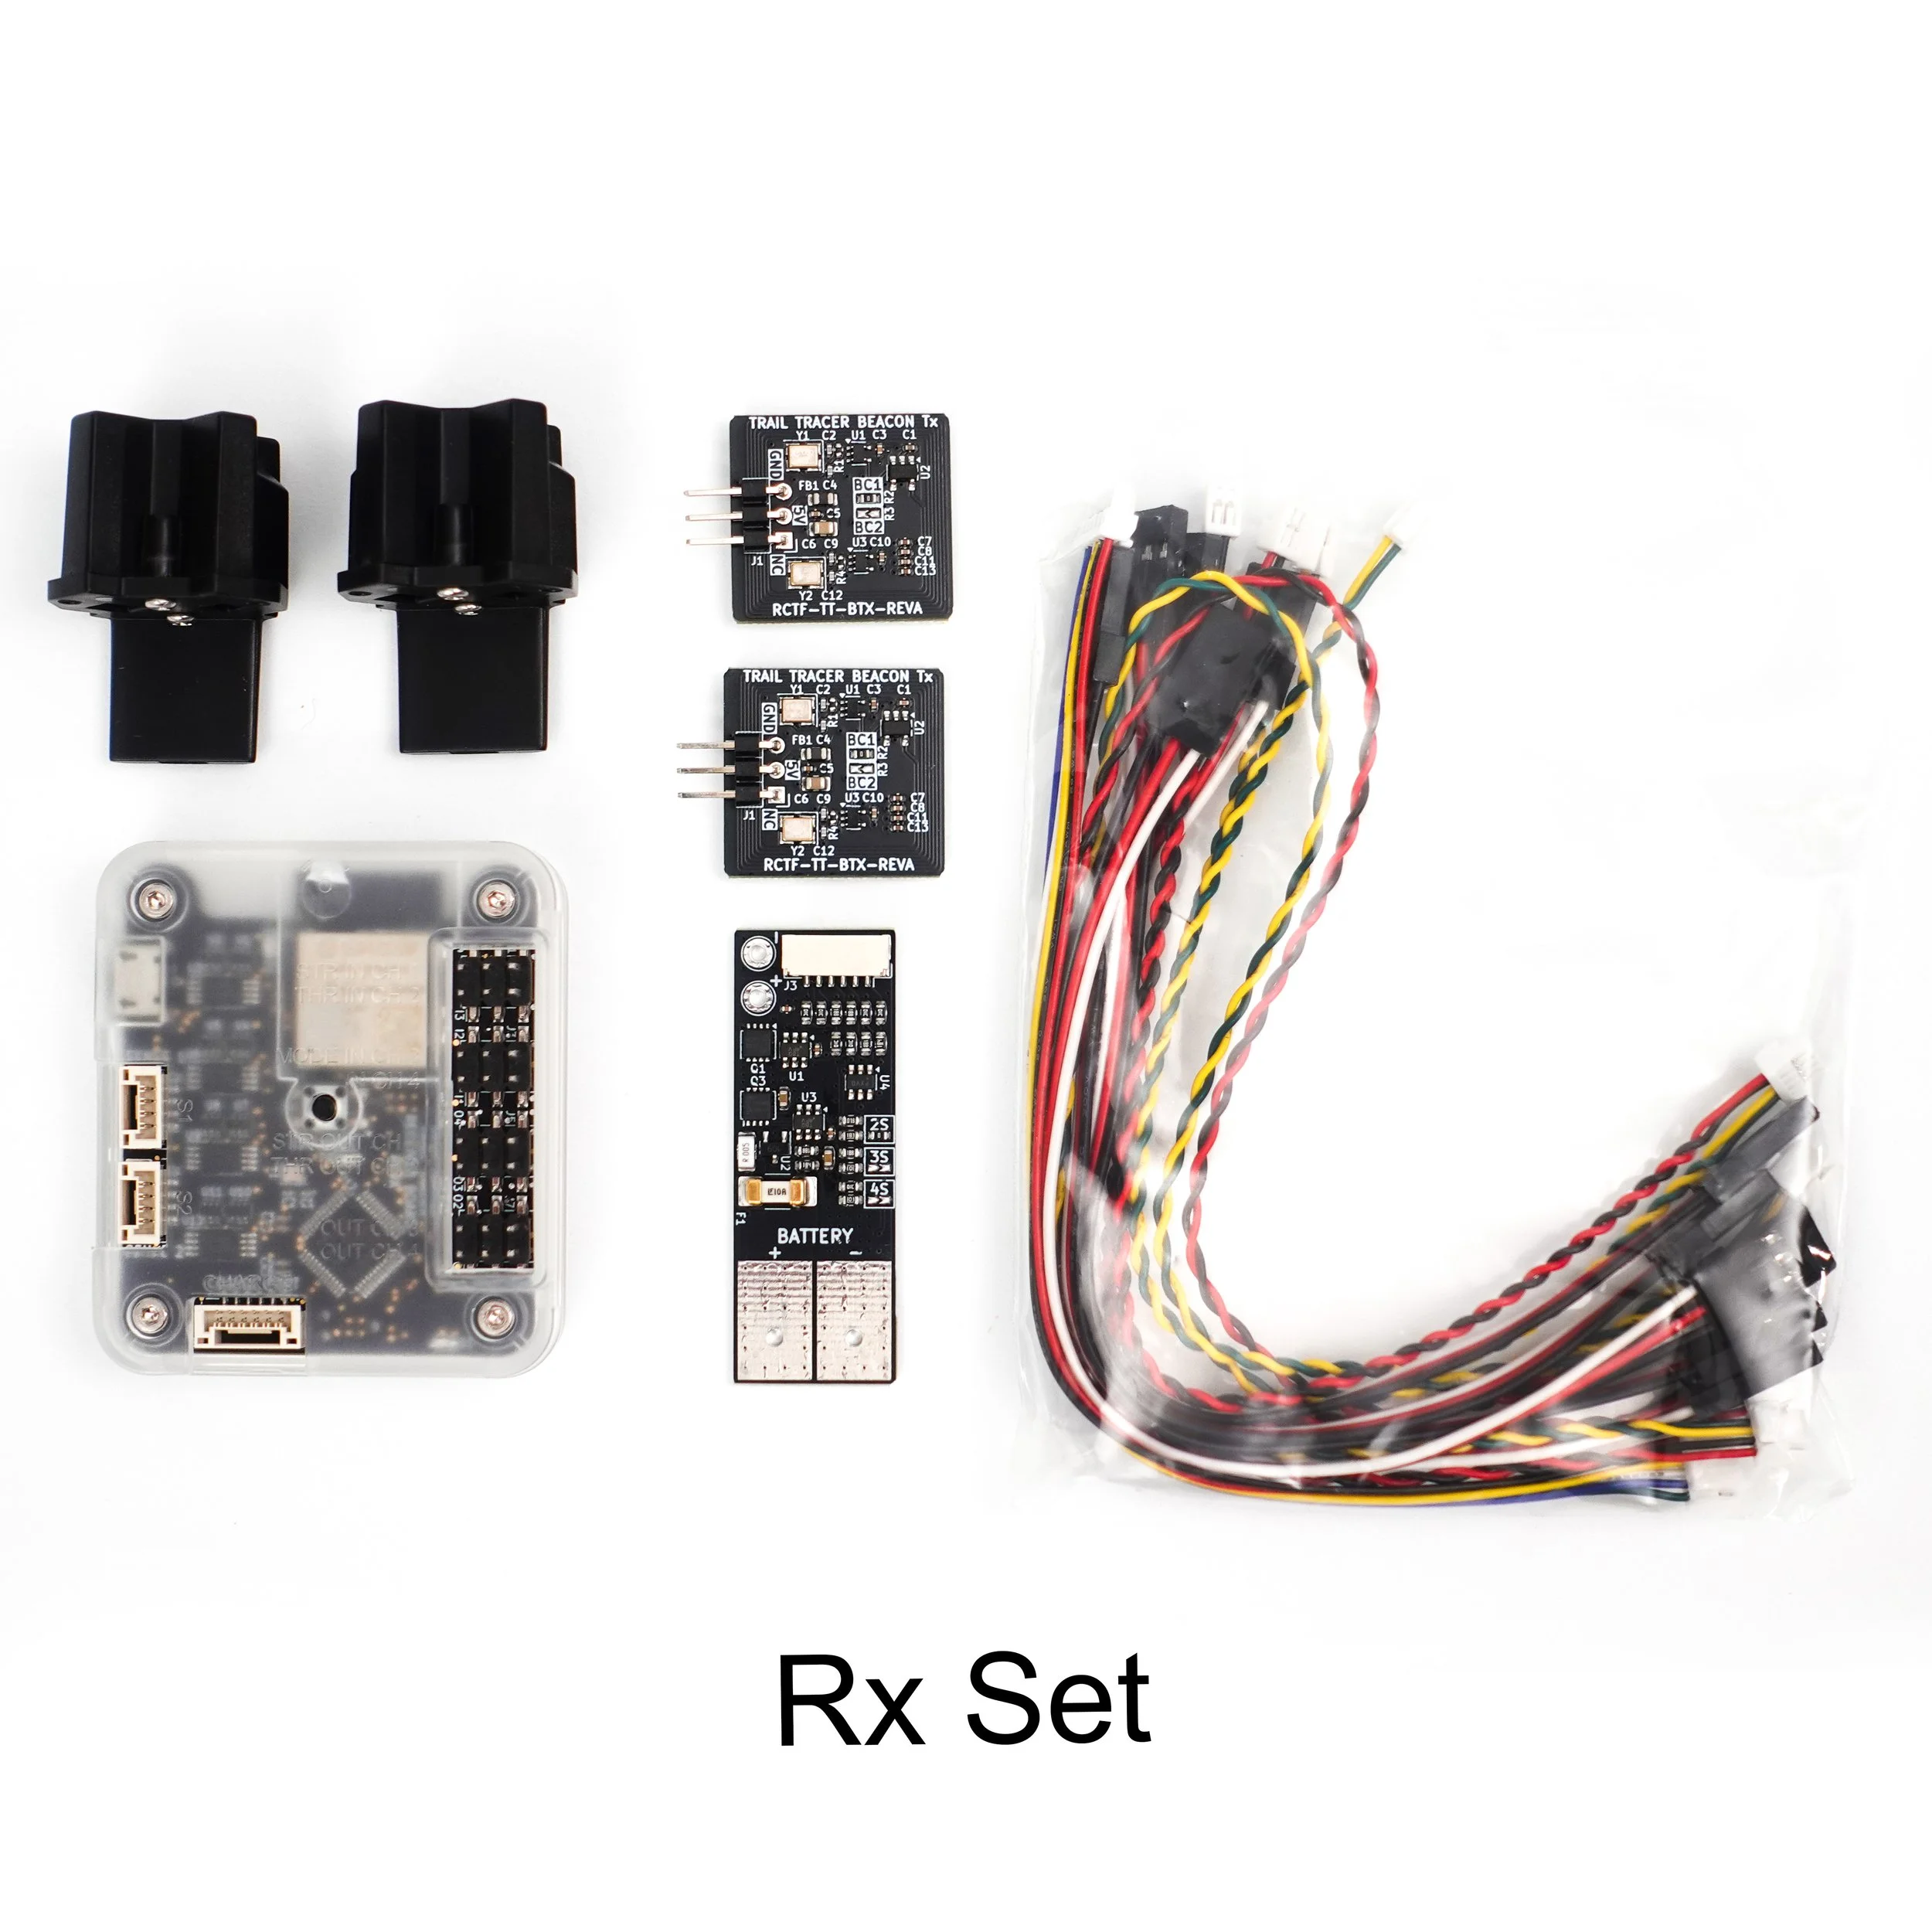
The Trail Tracer system turns any R/C car into a self driving, wire-following robot. It works best on low speed crawler type vehicles, but can also be used on higher speed vehicles with some tuning. The Rx Board easily fits on any vehicle 1/16th scale or larger, but can also fit on 1/18th and even 1/24th scale vehicles with some creativity. When paired with a Charge Port board, the vehicle can charge on its own and run indefinitely.
Required for use:
R/C car with ESC and Servo that use a standard PWM servo signal
20 AWG PVC Wire (or similar)
USB-C cable to power Tx Board, and 5V USB power source
Micro USB cable to connect Rx Board to PC
Advanced Components:
Charge system requires DIY construction of a charge port system (see advanced tutorial)
Instructions / Tutorial Videos:
https://docs.google.com/document/d/1xJ2LJ5pYNEHwpYQQPe2vaVs65cMxHG_B790lyTUjJ9g/edit?usp=sharing
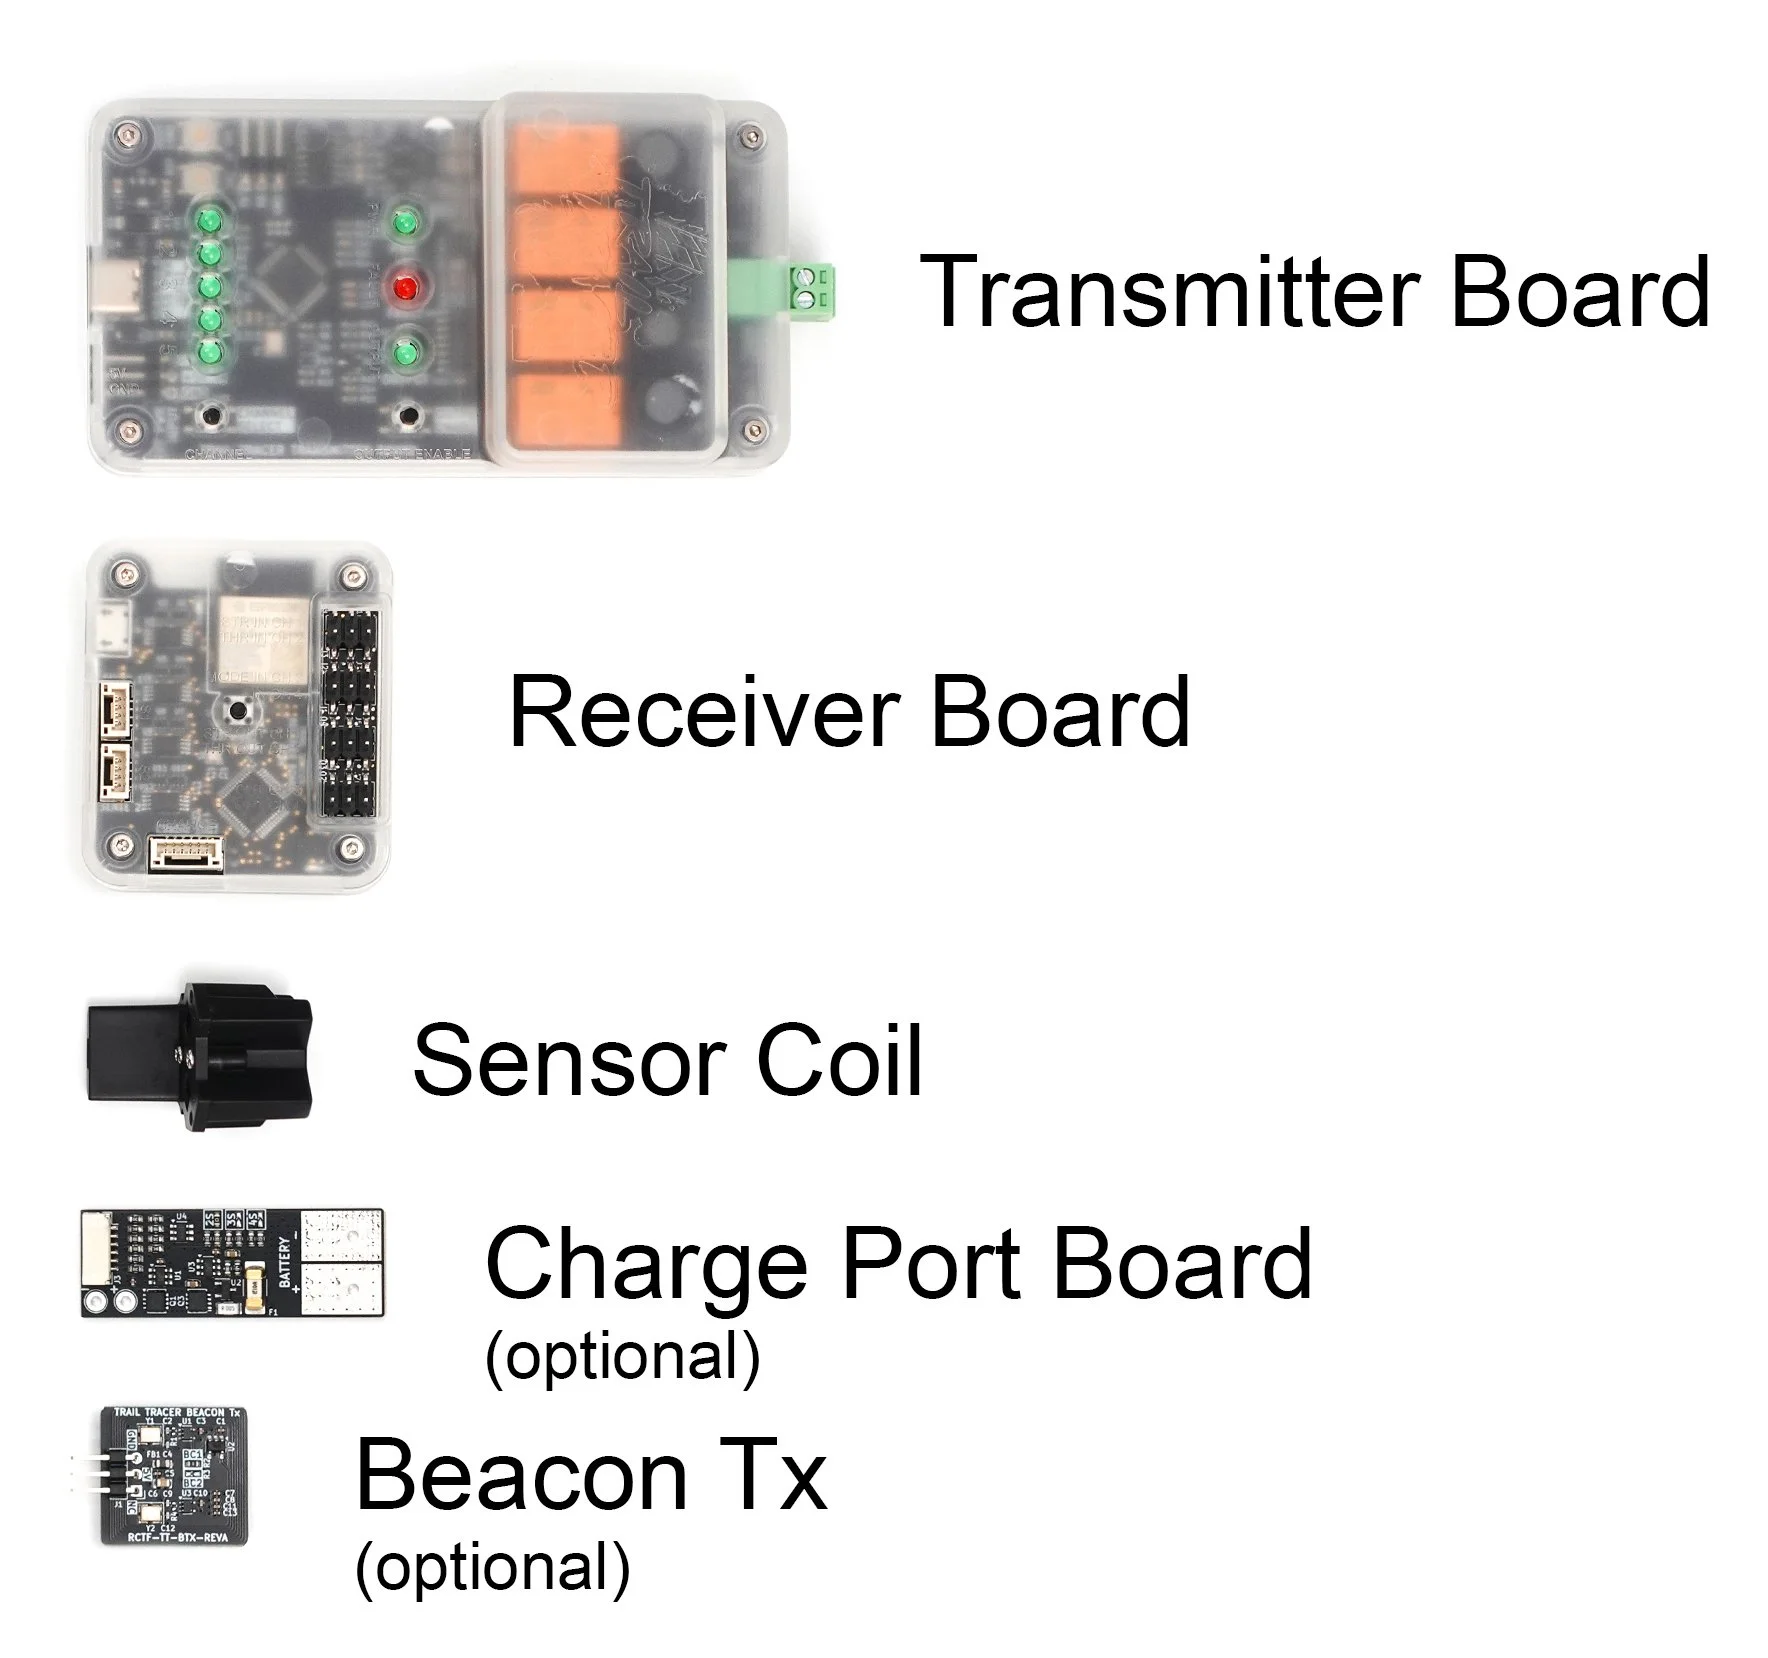
Component Description:
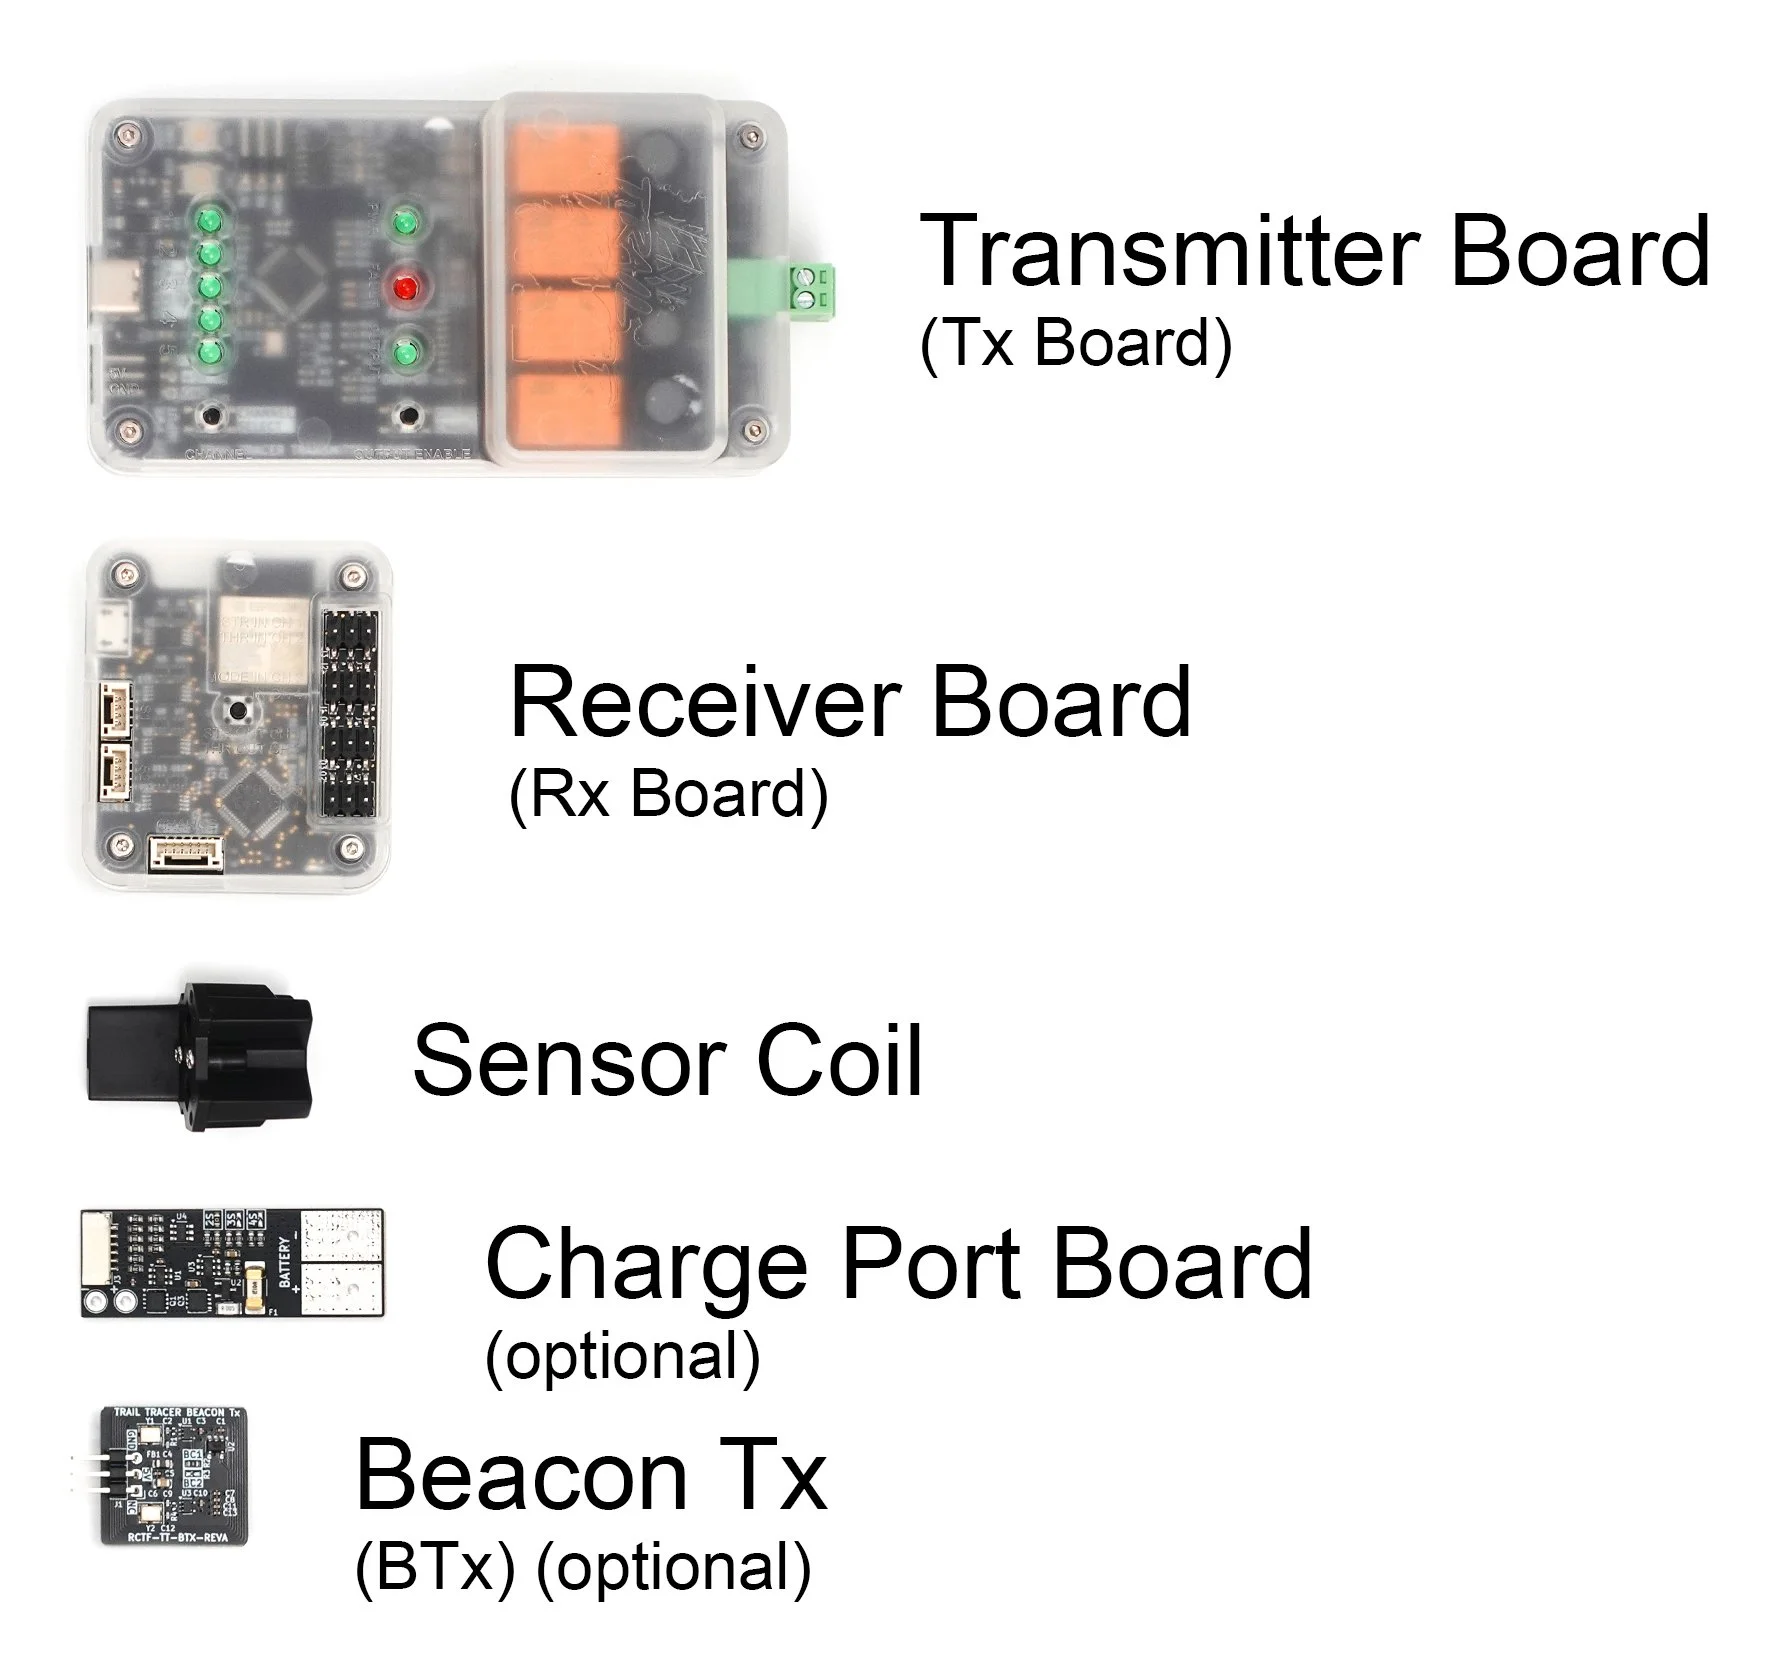
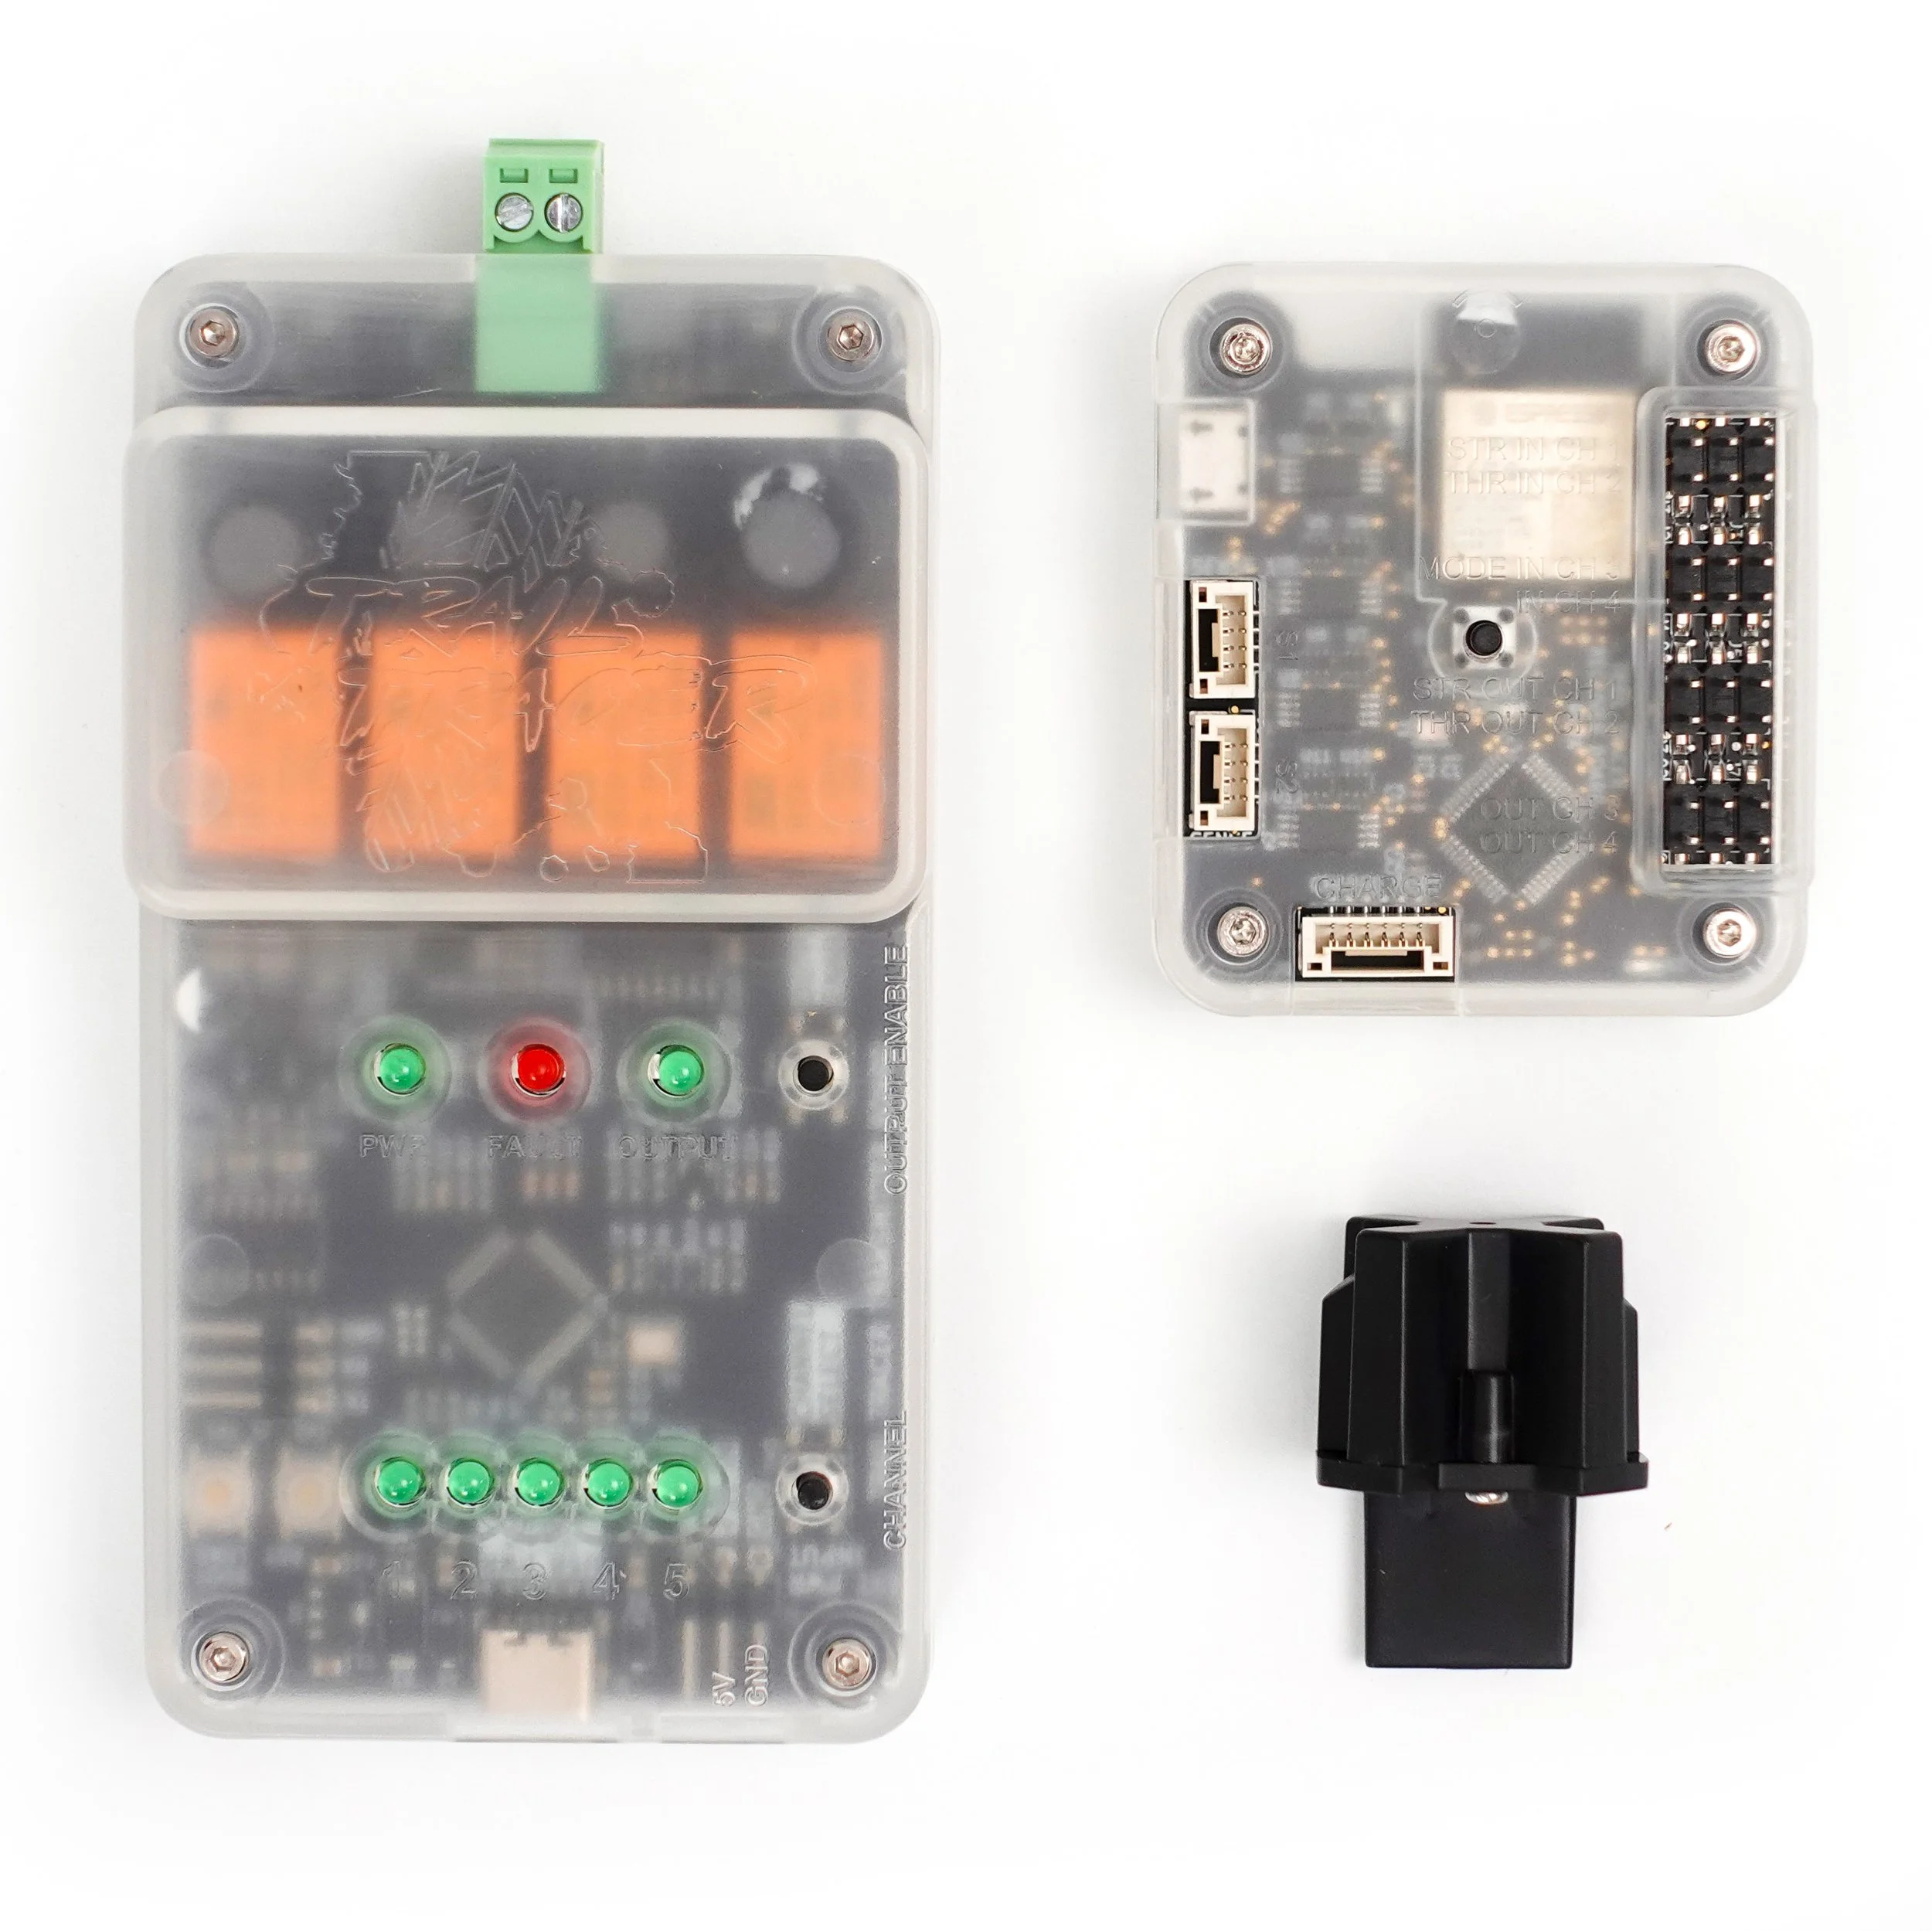
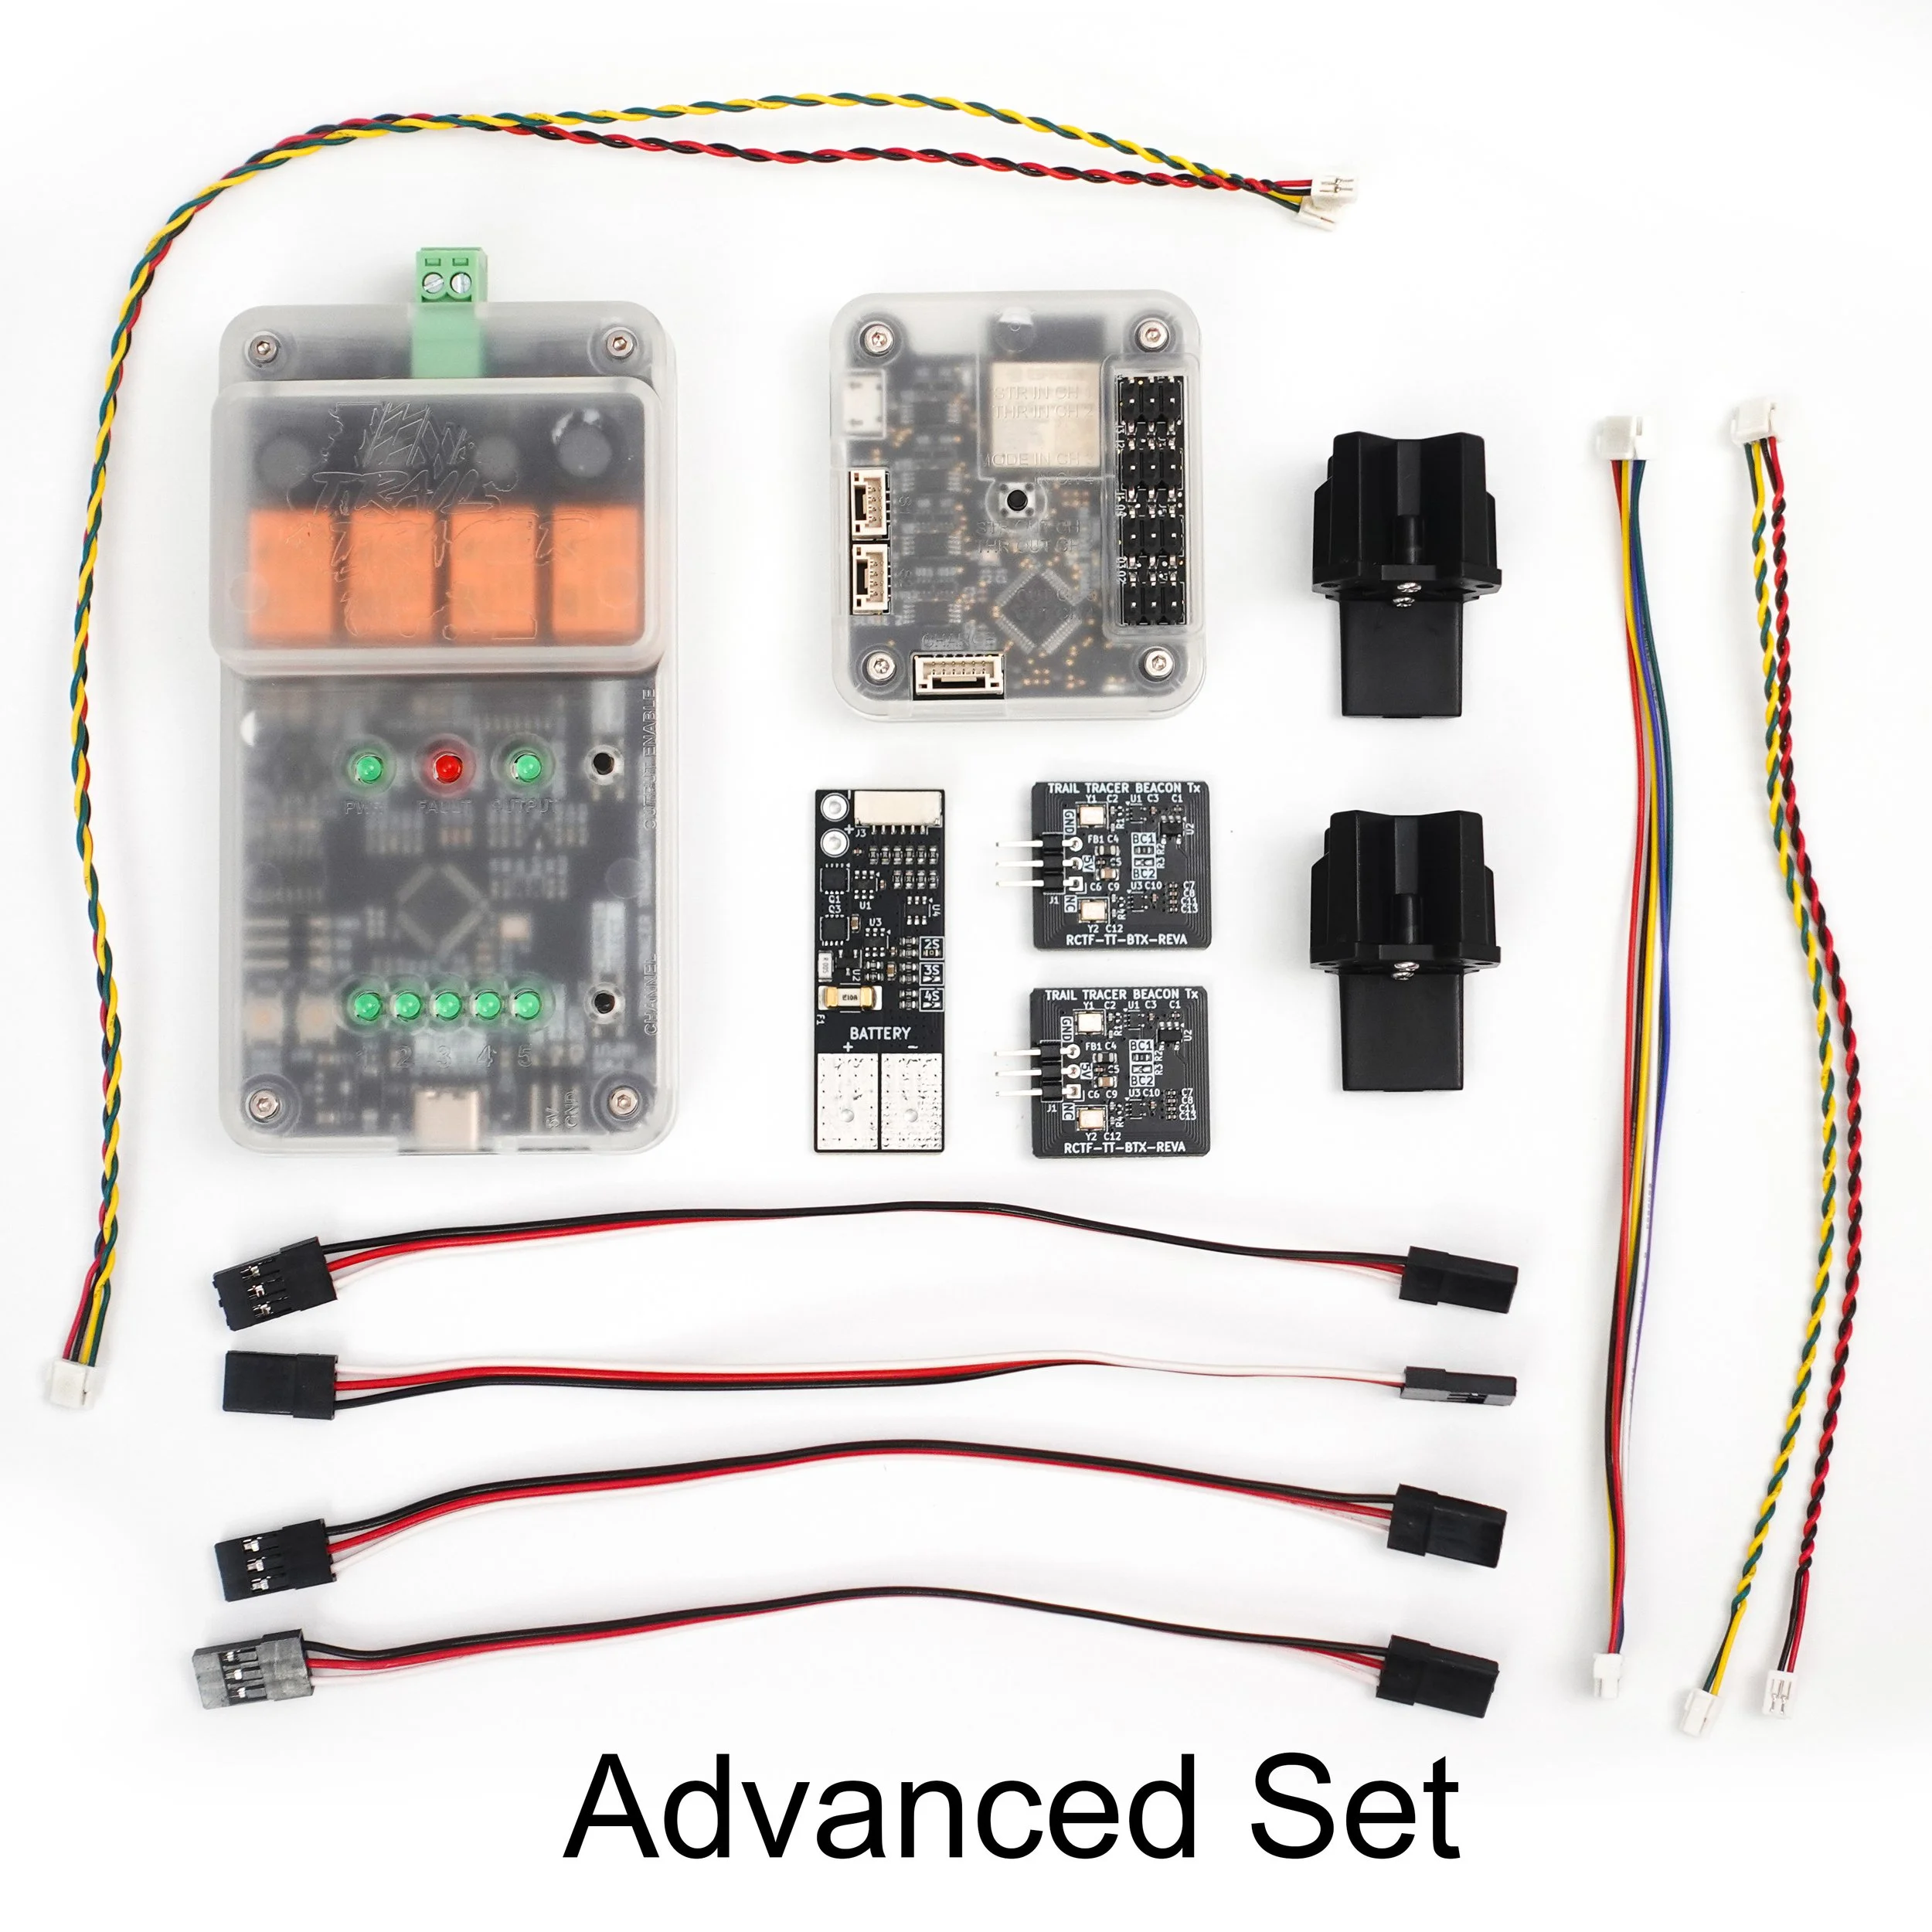
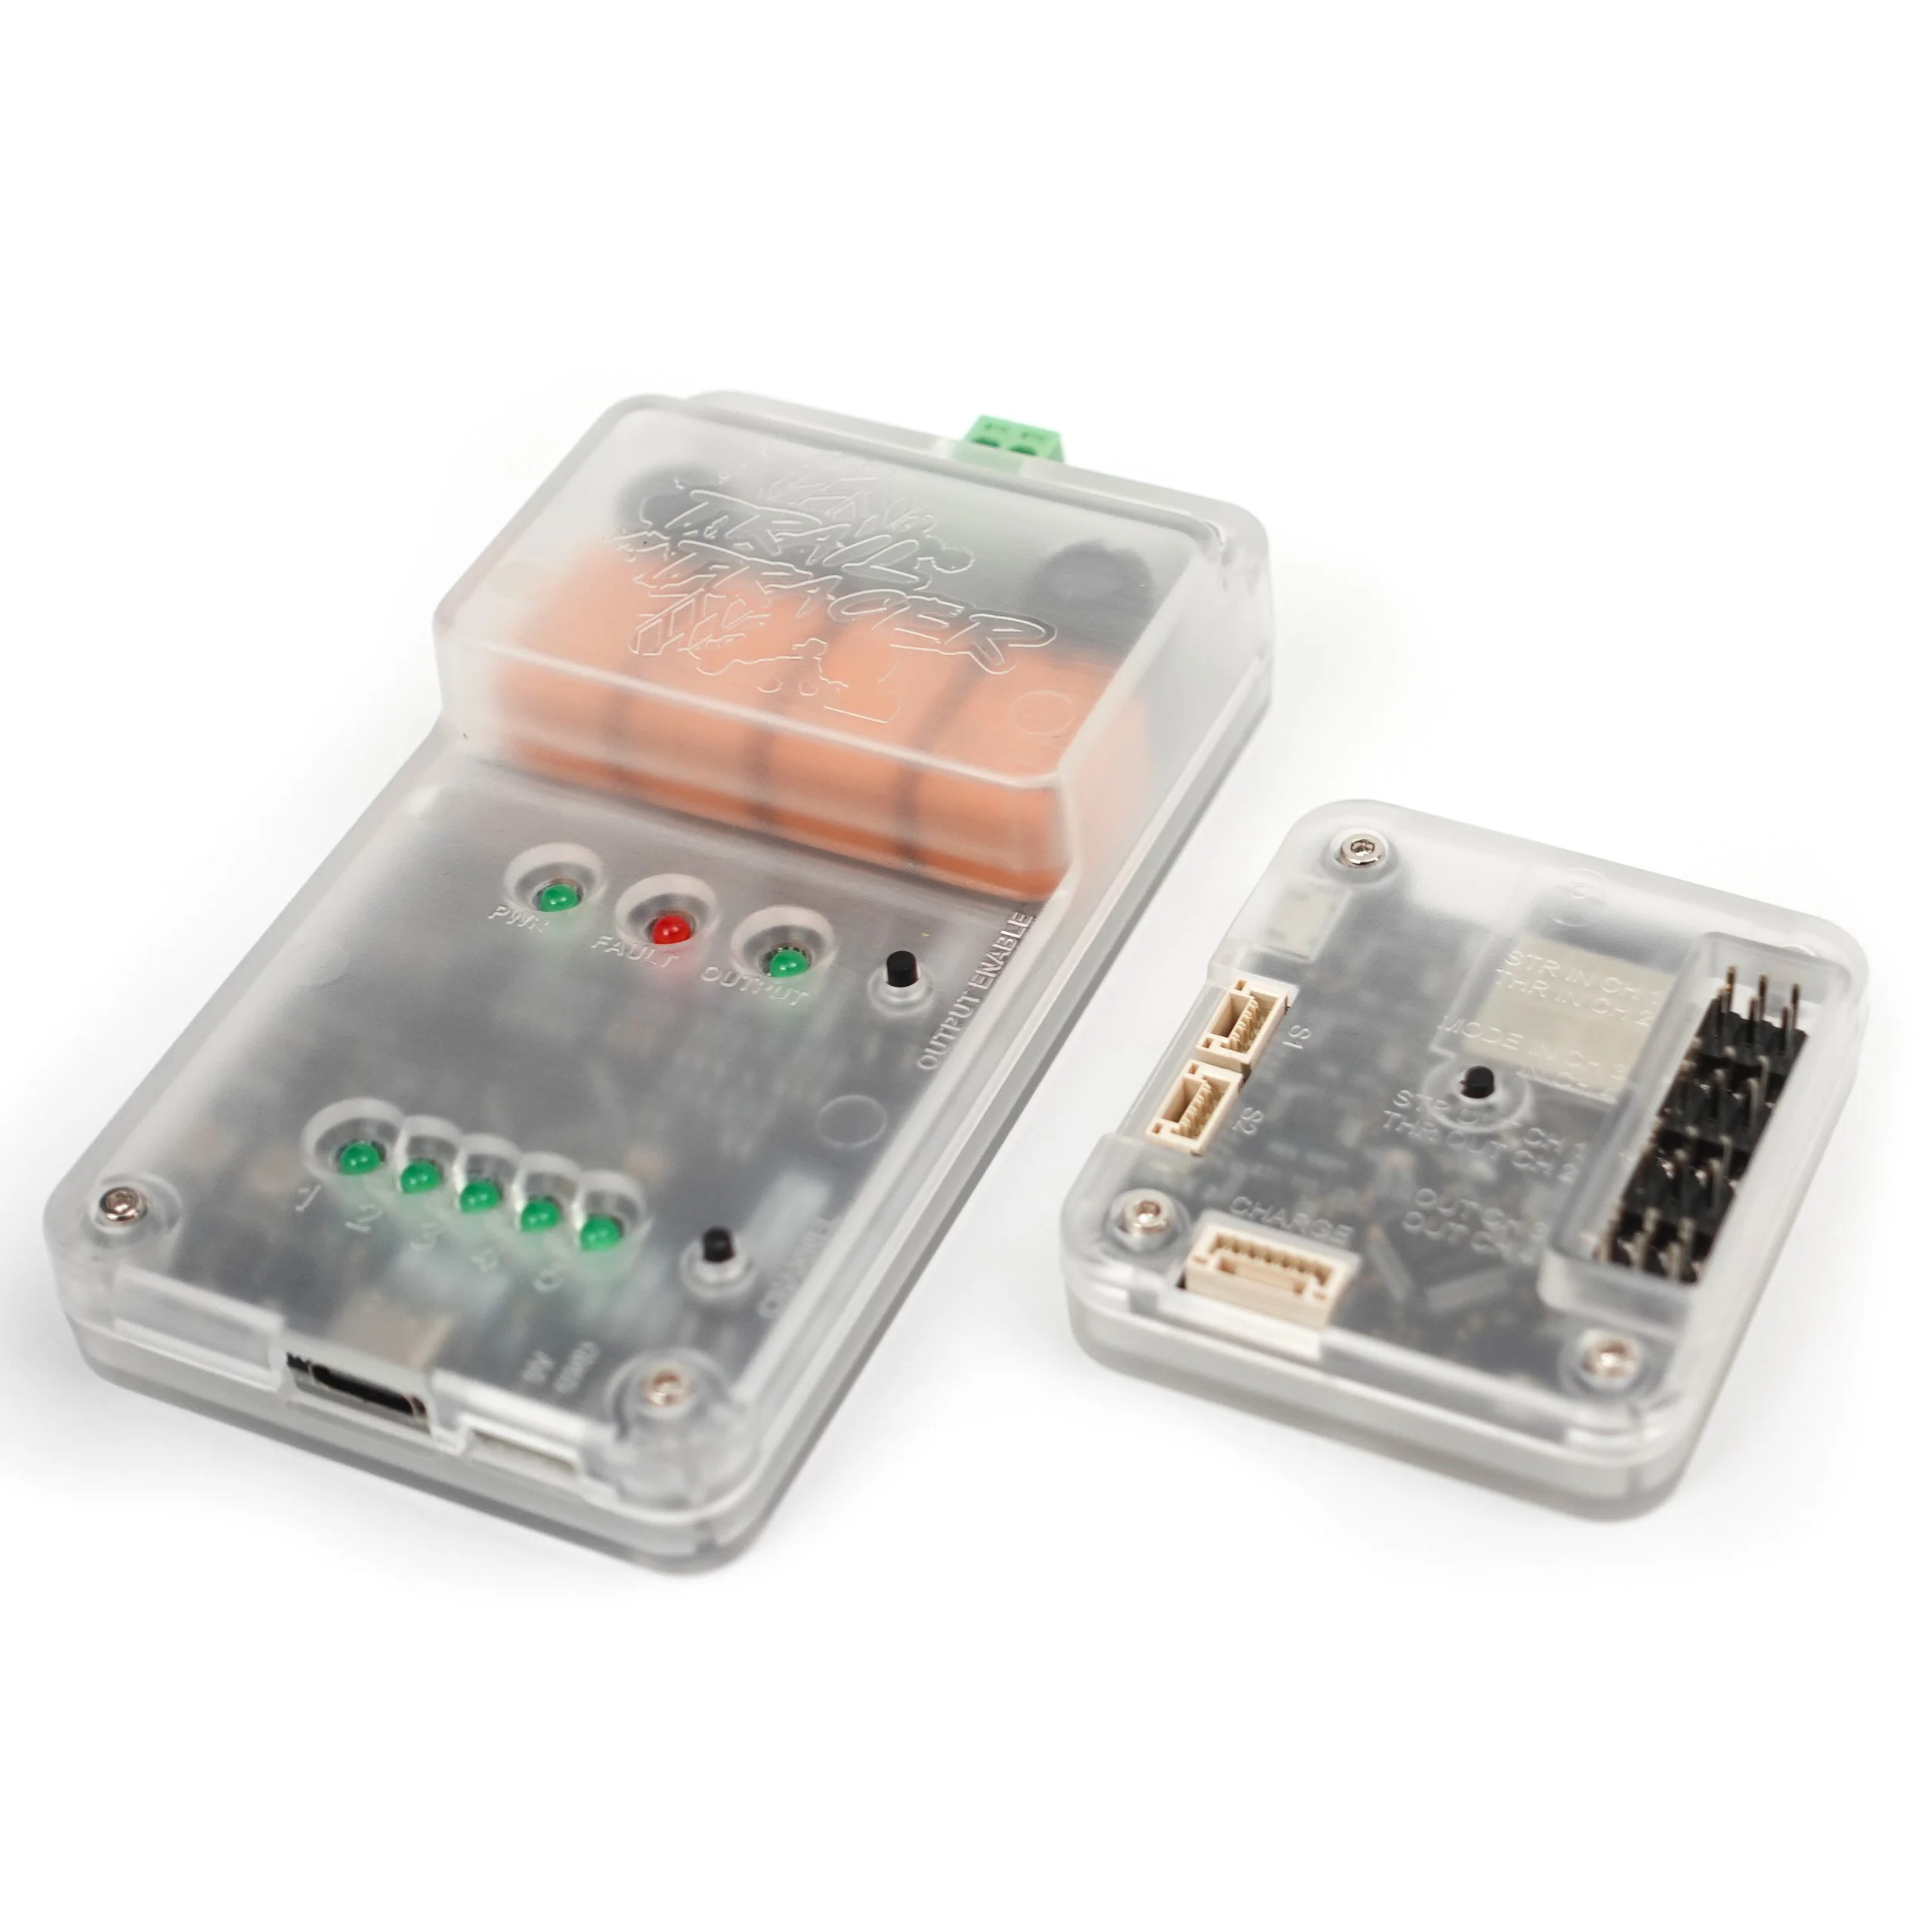
Transmitter Board: Generates the signal in the wire that the vehicle follows.
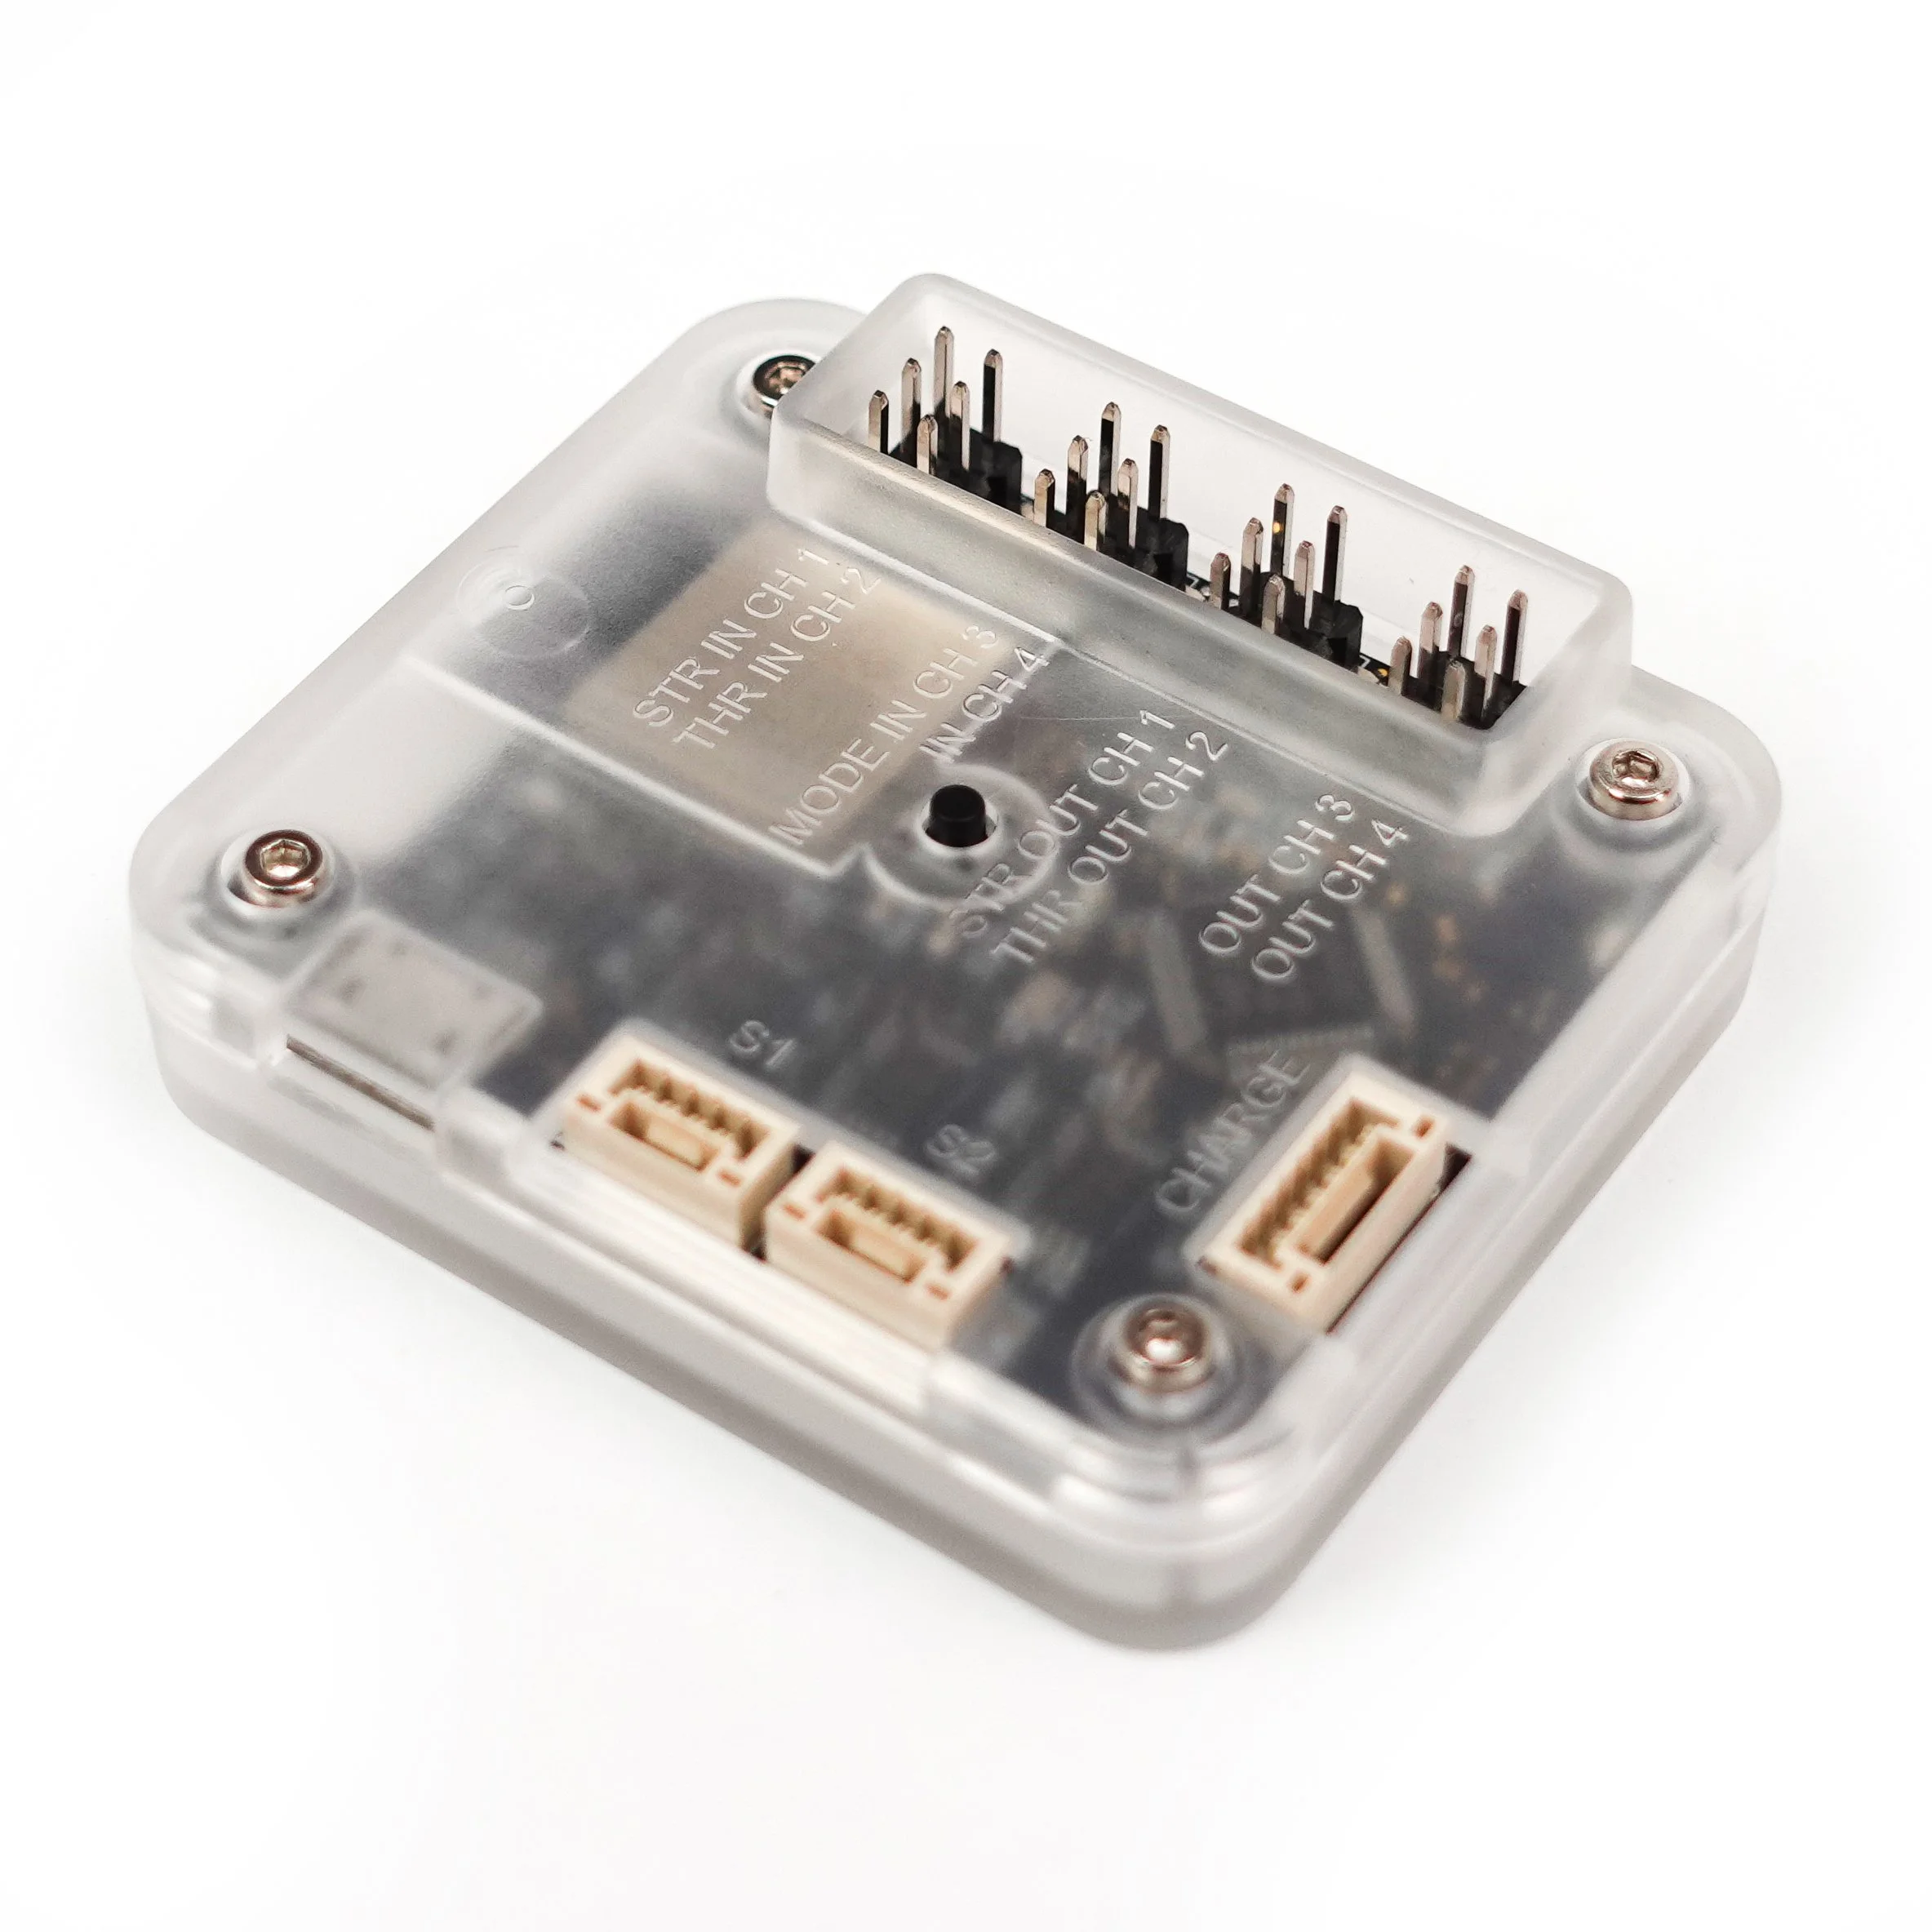
Receiver Board: The ‘brain’ of the vehicle. Reads the distance to the wire via the sensor coil and outputs the required steering servo signal to guide the vehicle along the wire. Controls throttle, and optionally reads R/C receiver outputs for manual control driving modes.
Sensor Coil: Contains two PCB wire coils that act as the ‘antennas’ that sense the wire signal.
Charge Port Board: Only used for automated charging control. Connects in-between the charge contacts and battery. Measures battery voltage and charge current for the Receiver Board to control charging.
Beacon Tx: Emits a signal on a different frequency than the Transmitter Board. The Receiver can detect this signal and use it to trigger various features like speed changes, sine-swerve mode, and multi-vehicle collision avoidance.